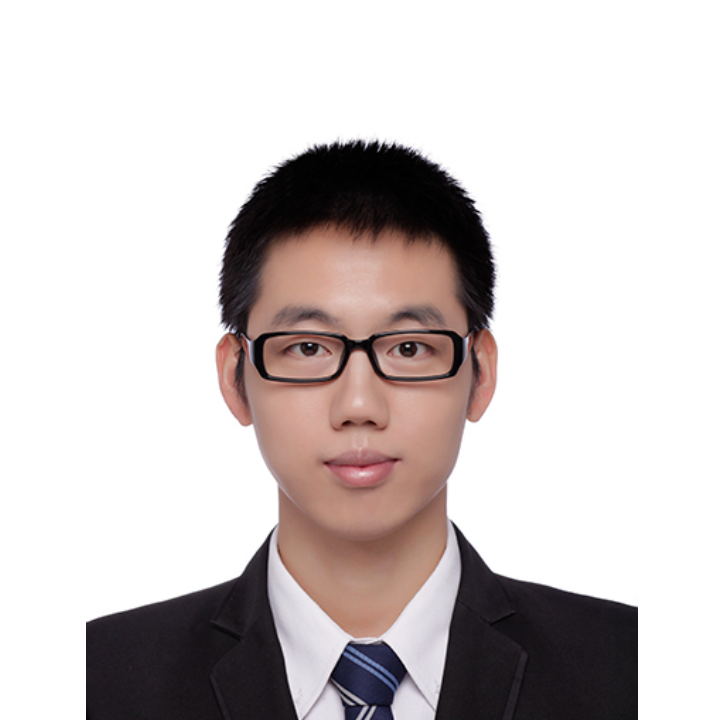
Biography
Teng Li is currently a Postdoctoral Research Fellow at The Hospital for Sick Children (SickKids) and the University of Toronto, Canada. His research interests include surgical robotics, robot control, intelligent control, robotic manipulation, teleoperation, physical human-robot interaction (pHRI), compliant control, haptics, and learning-based robotics, with an emerging focus on humanoid robotics and autonomous manipulation.
He received his Ph.D. in Biomedical Engineering from the University of Alberta, Canada, in 2024, his Ph.D. in Mechanical Design and Theory from Beihang University, China, in 2019, and his M.Eng. in Mechanical Manufacturing and Automation from Tianjin University of Science and Technology, China, in 2014.
Research Interests
- Surgical Robotics
- Robot Control Systems
- Intelligent Control
- Robotic Manipulation
- Teleoperation
- Physical Human-Robot Interaction (pHRI)
- Compliant Control
- Haptics
- Learning-Based Robotics
Hands-on Experience on Robots
7-DOF dVRK (da Vinci Research Kit) (Intuitive Surgical, Sunnyvale, CA, USA; ROS, Ubuntu, C++) 7-DOF Franka Emika Panda robot (Franka Emika GmbH, Munich, Germany; ROS, Ubuntu, C++) 7-DOF Kinova Gen3 Ultra lightweight robot (Kinova Robotics, Canada; ROS, Ubuntu, C++) 6-DOF 3D Systems Touch (formerly Phantom Omni) (3D Systems, Inc., Cary, NC, USA; ROS, Ubuntu, C++) 6-DOF HD2 (High Definition Haptic Device) (Quanser Inc., Markham, ON, Canada; MATLAB/Simulink) 3-DOF PHANToM Premium 1.5A robot (3D Systems, Inc., Cary, NC, USA; MATLAB/Simulink) 2-DOF planar Rehabilitation robot 1.0/2.0 (Quanser Inc., Markham, ON, Canada; MATLAB/Simulink)
Updated 2026-09-22, Created 2024-04-05.